This signal is still in the schedule queue.
MIT's New Open-Source Drone Swarm Algorithm
Multi-agent collision avoidance is usually a computational nightmare. Enter MIGHTY, an open-source trajectory planner from MIT. Using Hermite splines, it lets UAVs and rovers navigate and dodge dynamic obstacles in real-time. It is fully integrated with ROS 2, so you can go straight from simulation to real hardware. Stop wrestling with heavy math. This peer-reviewed code solves the multi-robot routing problem efficiently.
More signals
01
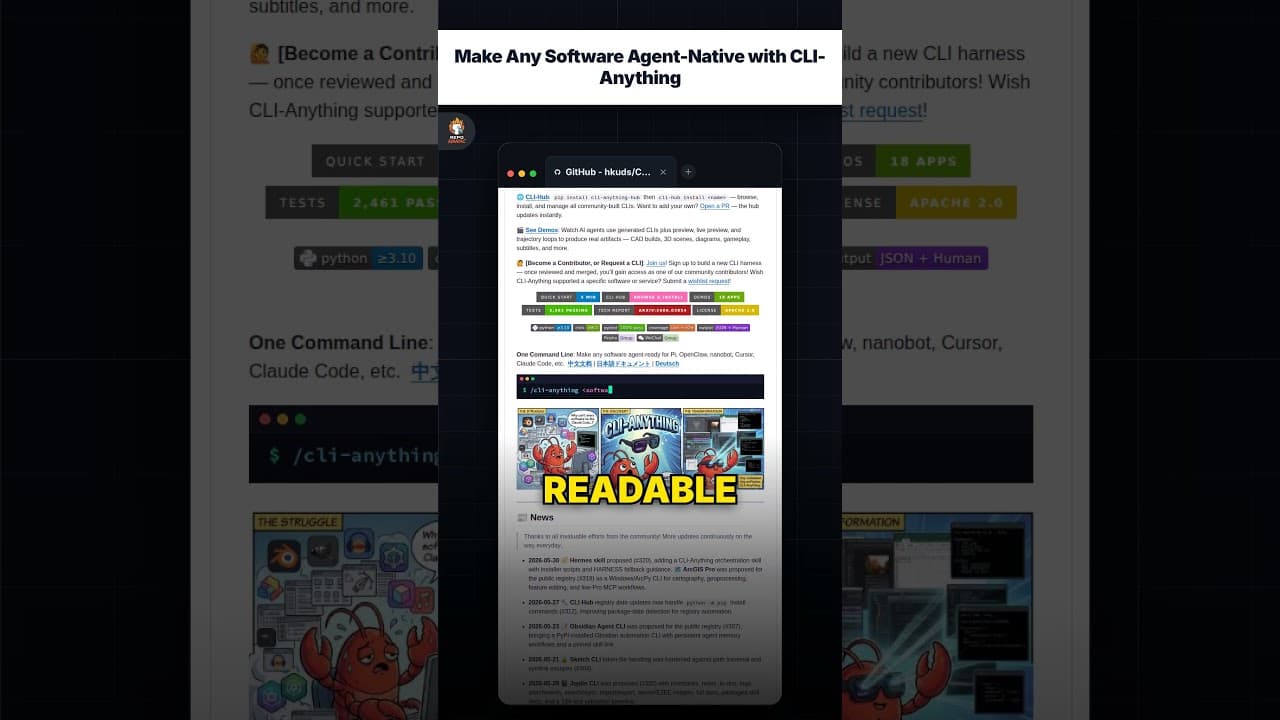
Make Any Software Agent-Native with CLI-Anything
00:39Sep 07, 2026score98
02
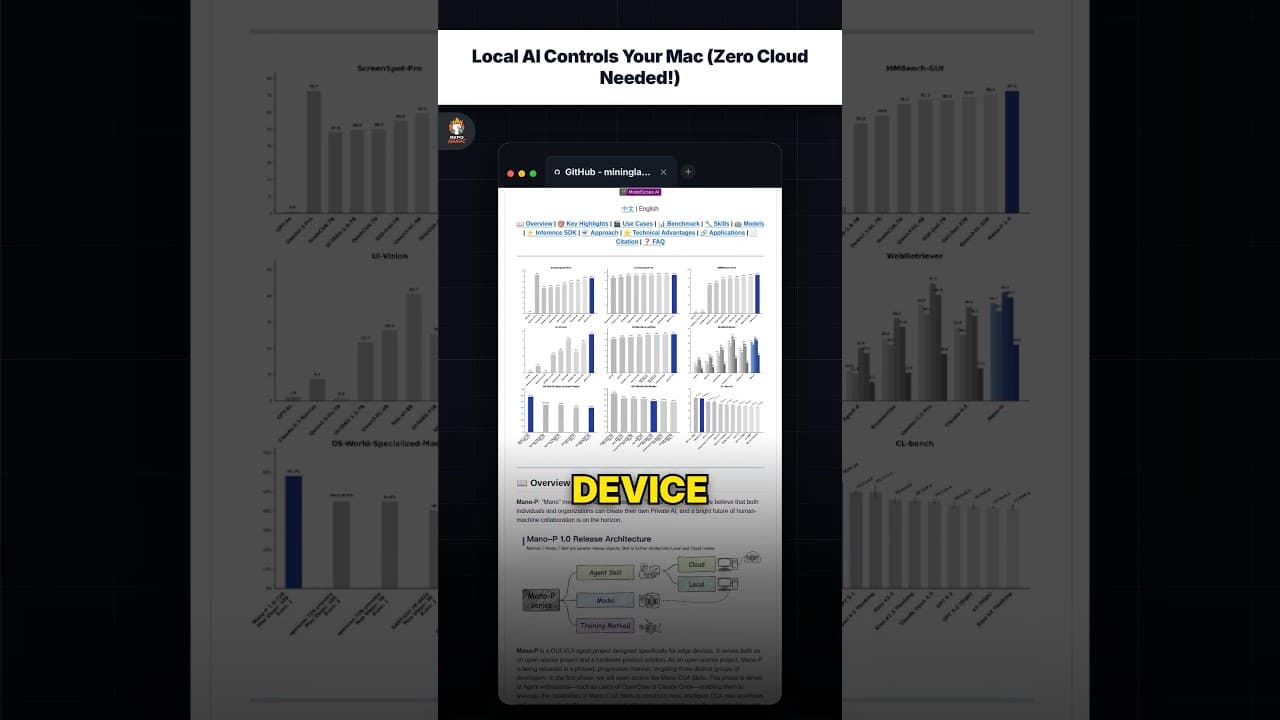
Local AI Controls Your Mac (Zero Cloud Needed!)
00:33Sep 06, 2026score95
03
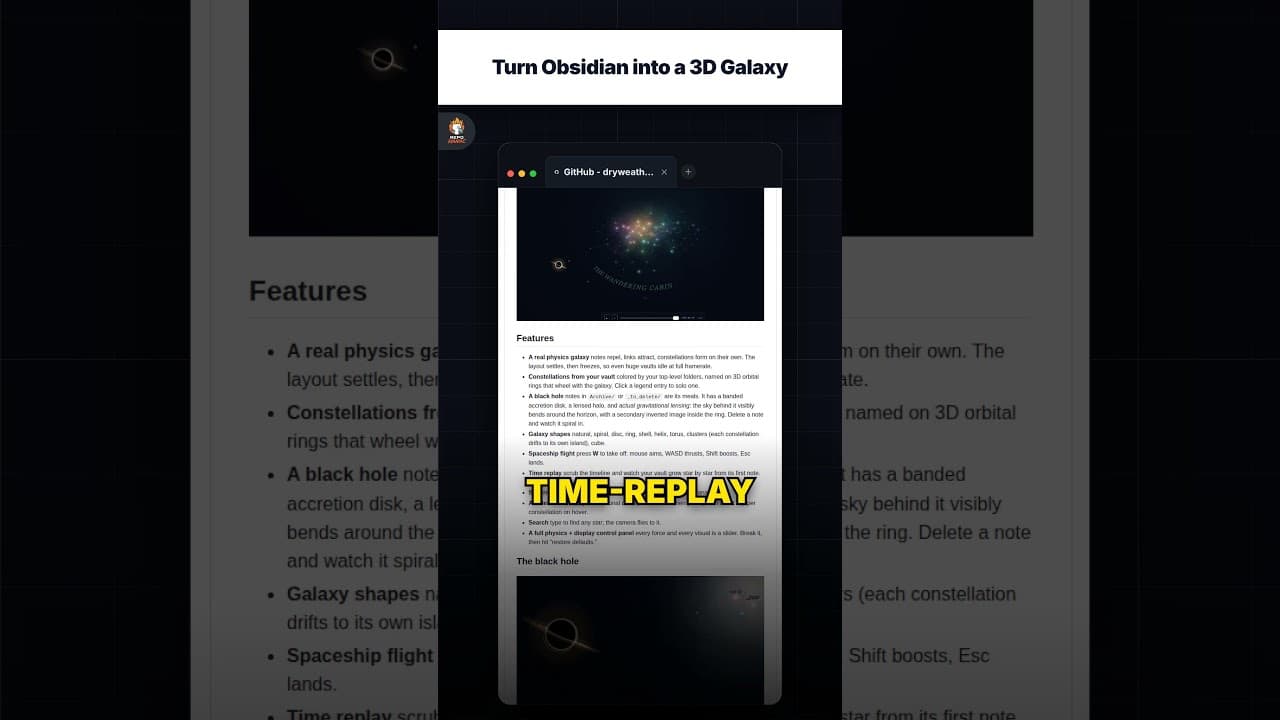
Turn Obsidian into a 3D Galaxy
00:35Sep 05, 2026score95